01
Generate worlds
Language and diffusion models turn a text prompt or a 2D floorplan into a furnished, human-centric 3D world, drawing on a semantically annotated model database.
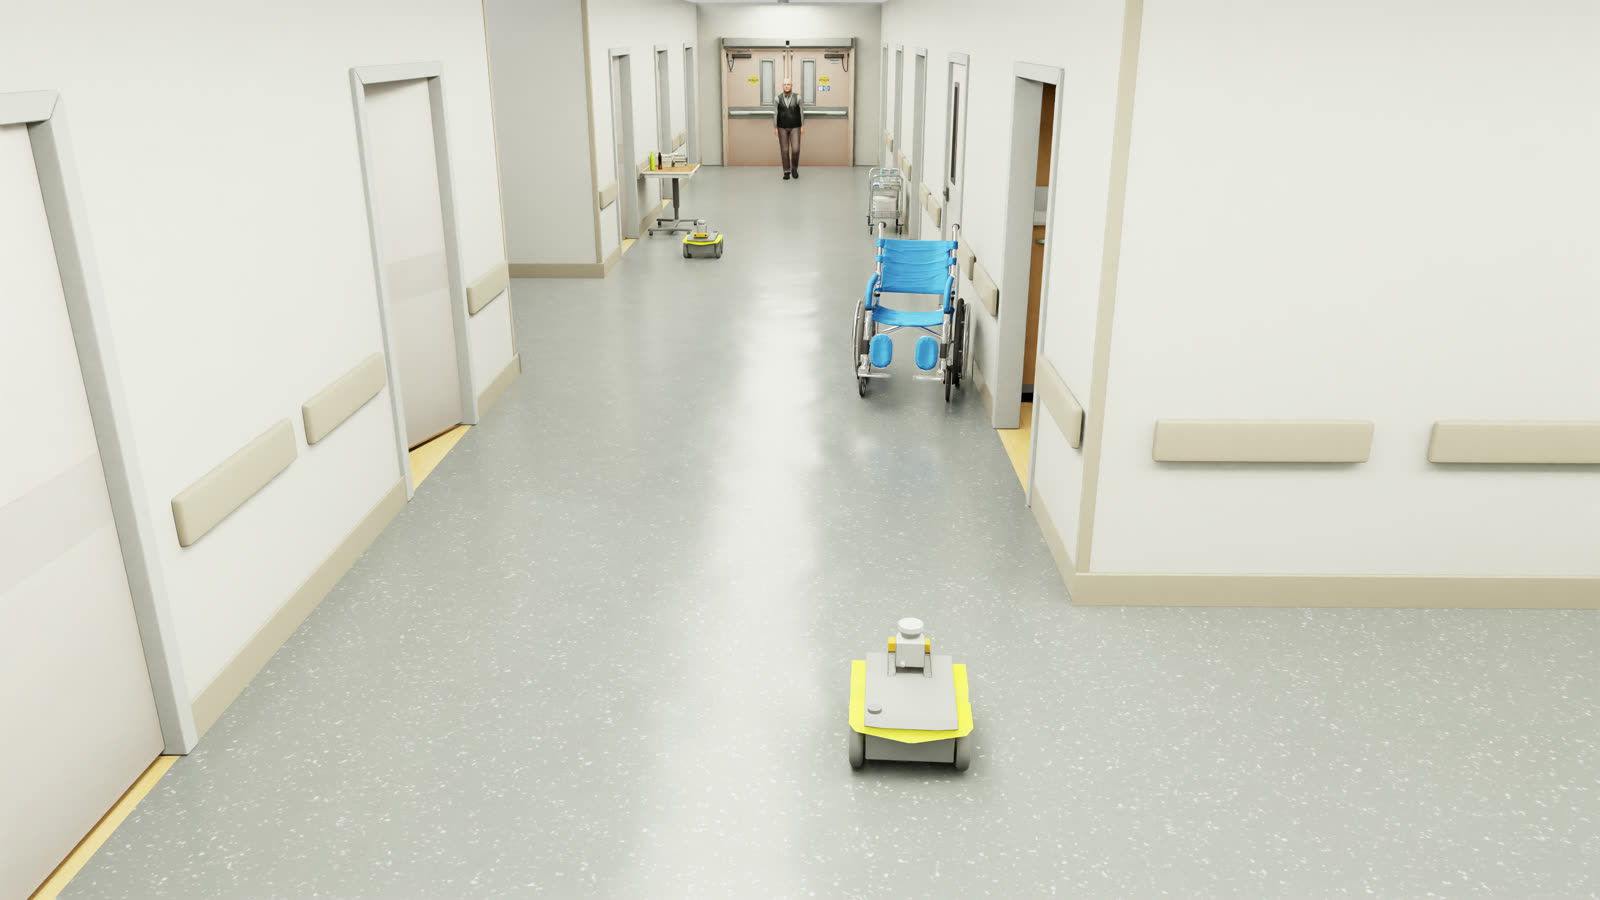
Arena-Rosnav is an open-source ROS 2 platform to generate human-centric worlds, simulate crowds, train planners and benchmark them, from fast 2D Flatland to photorealistic Isaac Sim.
Isaac Sim, hospital world, PEDS pedestrians
The platform
Modules are abstracted across simulators, so a scenario you design once can run in 2D for training and in photorealistic 3D for evaluation.
Language and diffusion models turn a text prompt or a 2D floorplan into a furnished, human-centric 3D world, drawing on a semantically annotated model database.
Swap between six pedestrian drivers, from social force to learned models, with groups, queues and need-driven behavior trees.
Train DRL agents with Stable-Baselines3 from a single config file, with multiprocessed rollouts, curricula and faster-than-real-time 2D simulation.
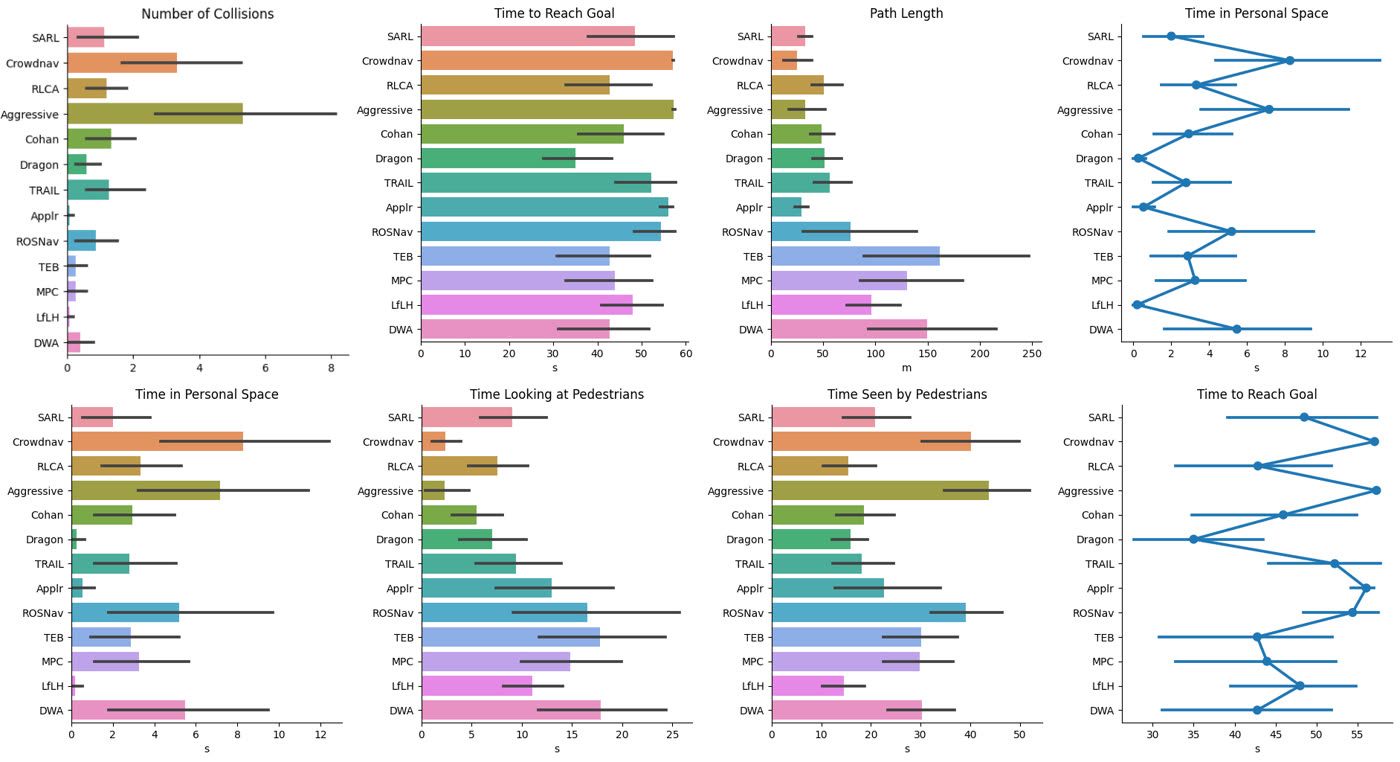
One click runs planners across worlds and scenarios and records collisions, path length and time to goal, plus social metrics such as time in personal space.
Simulators
Pick the simulator for the job and keep the same worlds, robots, pedestrians and task modes.
Benchmark
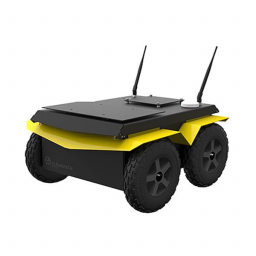
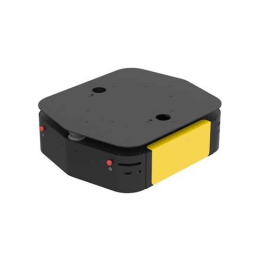
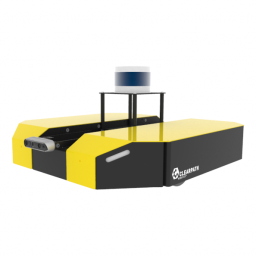
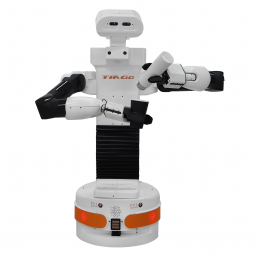
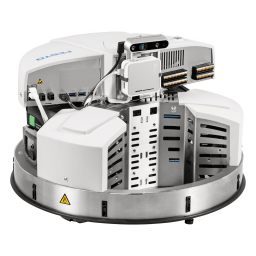
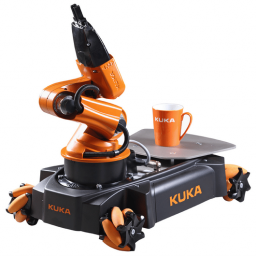
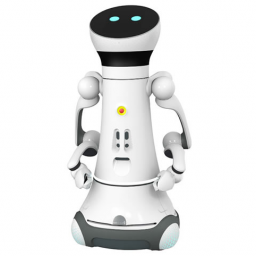
Classic, learned and socially aware planners ship ready to run, on robots from small differential drives to quadrupeds.
Papers

IEEE RA-L 2026 To be presented at ICRA 2027
Social navigation benchmarks quietly fix one pedestrian model. PEDS makes it a variable, and robot policy rankings reorder depending on which crowd model you test against.

RSS 2025
Complete NVIDIA Isaac Gym integration, a benchmark of state-of-the-art social navigation planners, and scenario generation for emergency and rescue situations.

arXiv 2024
Worlds generated from text prompts or floorplans with LLMs and diffusion models, a semantic 3D model database, and the move to ROS 2.

RSS 2024
New social force models and human-robot interaction patterns, new task modes, and one abstraction over Flatland, Gazebo and Unity.